Robotics · Control · Learning

Suryaprakash
Rajkumar

PhD Researcher · Concordia University

Suryaprakash Rajkumar
PreCySe Group
Montréal, Canada

I am a PhD researcher in Information Systems Engineering at Concordia University, supervised by Prof. Walter Lucia in the Predictive Cyber-Physical System Security (PreCySe) Group. My research focuses on enabling autonomous robots to operate safely, reliably, and efficiently by combining model-based control with data-driven learning.

My work spans learning-based trajectory tracking, set-theoretic collision avoidance, and predictive control for autonomous and multi-agent robotic systems. A central goal of my research is to bridge rigorous safety and control guarantees with computationally efficient methods that can be implemented in real time on affordable robotic platforms.

Research interests
Mobile and aerial robotics · Optimal and predictive control · Imitation learning · Safe multi-agent systems

Publications & Manuscripts

Google Scholar ↗
Manuscript

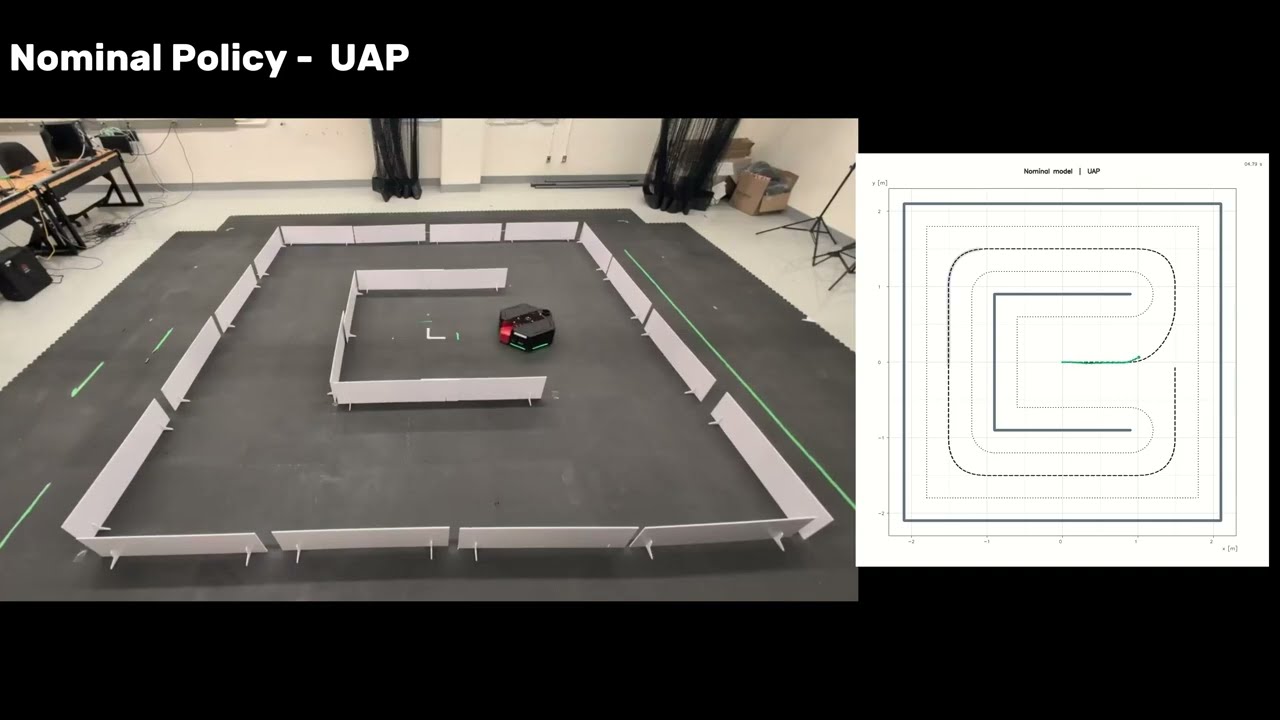
Universal Perturbation Attacks on Neural Network Controllers for Wheeled Mobile Robots

Suryaprakash Rajkumar, Ehsan Eslami, Walter Lucia, Amr Youssef

IEEE Transactions on Control Systems Technology (TCST), submitted

Research figureNominal neural-network controller under a universal adversarial perturbation attack
Manuscript

Backdoor Poisoning of Federated Neural Network Controllers for Differential-Drive Robots

Suryaprakash Rajkumar, Ehsan Eslami, Walter Lucia, Amr Youssef

IEEE Transactions on Industrial Informatics, submitted
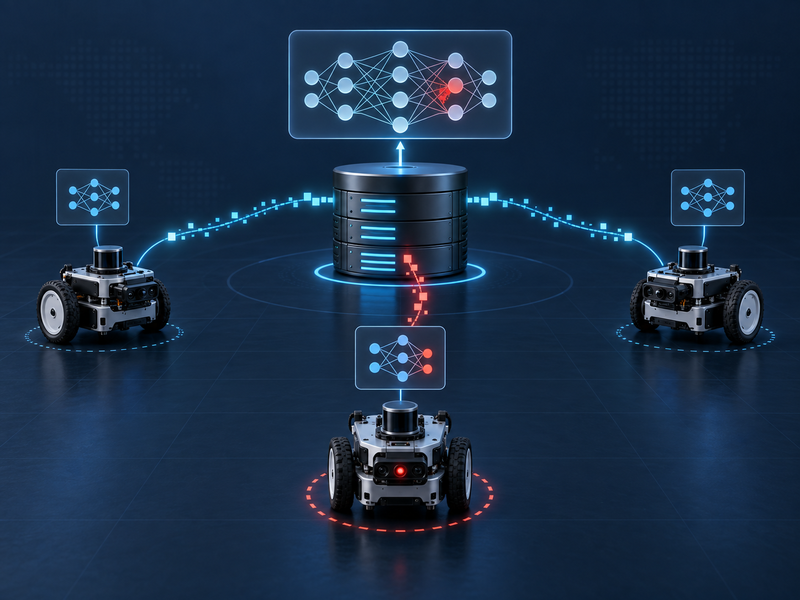
Research figureConceptual illustration of backdoor poisoning in federated robot controllers
Manuscript

Guaranteed Set-Theoretic Collision Avoidance in Multi-Agent Mobile Robotic Systems

Suryaprakash Rajkumar, Walter Lucia

Manuscript in preparation for IEEE Transactions on Robotics (T-RO)

Research figureCollision Avoidance Publication
Published

A Real-Time Affordable Predictive Trajectory Tracking Controller for Differential Drive Robots via Imitation Learning

Suryaprakash Rajkumar, Walter Lucia

IEEE 22nd International Conference on Automation Science and Engineering, 2026

Research figureCASE Publication
Published

A Set-Theoretic Control Strategy for a Platoon of Differential-Drive Robots with Inter-Vehicle Collision Avoidance

Suryaprakash Rajkumar, Walter Lucia

IEEE Transactions on Automation Science and Engineering, 2026

Research figureTASE Publication
Published

Collision-Free Platooning of Mobile Robots through a Set-Theoretic Predictive Control Approach

Suryaprakash Rajkumar, Cristian Tiriolo, Walter Lucia

2024 American Control Conference (ACC), pp. 608-613, July 2024

Research figureACC Publication
Poster

Robust Set-Theoretic MPC-Based Guidance for Guaranteed Collision Avoidance in Multi-Agent Robotic Systems

Suryaprakash Rajkumar

Biannual Meeting on Systems and Control Theory (MSCT), Waterloo, Canada, 2023

Research figureMSCT Poster
Published

ME-CapsNet: A Multi-Enhanced Capsule Networks with Routing Mechanism

Suryaprakash Rajkumar, Jerrin Bright, Arockia Selvakumar

IEEE International Conference on Electronics, Computing & Communication Technologies, Bangalore, India, 2022

Research figureCONECCT Publication
Published

Optimization of Quadcopter Frame Using Generative Design and Comparison with DJI F450 Frame

Suryaprakash Rajkumar, Jerrin Bright, Akash S, Giridharan A

International Conference on Robotics, Intelligent Automation and Control Technologies, Chennai, India, 2021

Research figureRIACT Publication
Poster

Event-Based Dynamic Obstacle Avoidance for Outdoor Environments

Suryaprakash Rajkumar

International Conference on Intelligent Robots and Systems (IROS), Prague, Czech Republic, 2021

Research figureIROS Poster

Education

PhD in Information Systems Engineering

Sept 2024 - Present

Concordia University

Montreal, Canada

  • Supervisor: Prof. Walter Lucia
  • Group: Predictive Cyber-Physical System Security Group (PreCySe)
  • Courses: Multi-agent Systems, Nonlinear Systems

MASc in Quality Systems Engineering

Sept 2022 - Aug 2024

Concordia University

Montreal, Canada

  • Supervisor: Prof. Walter Lucia
  • Group: Predictive Cyber-Physical System Security Group (PreCySe)
  • Courses: Linear System, TQM, Advanced Statistics, Cyber-physical Systems

B.Tech in Mechanical Engineering

Sept 2018 - Aug 2022

Vellore Institute of Technology

Chennai, India

  • Supervisor: Prof. Arockia Selvakumar
  • Courses: Control Systems, Mechatronics, Mechanics, Thermodynamics, System Design

Teaching & Research Experience

Part-time Lecturer

Nov 2025 - Jan 2026

Tecnológico de Monterrey

Monterrey, Mexico

  • Taught Mobile Robotics (control, filtering/estimation, kinematics/dynamics, and optimal control).
  • Designed the course syllabus, assignments, and assessments; mentored student projects from modeling and estimation to optimal control.

Research Intern

Nov 2021 - Apr 2022

ARTPARK, Artificial Intelligence and Robotics Laboratory, IISc

Bangalore, India

  • Worked on event vision based end-to-end agile navigation of a quadrotor in a cluttered environment
  • Developed and deployed a module for event-to-depth prediction using a spiking neural network for efficient monocular depth prediction for dynamic obstacle avoidance intended to be used on neuromorphic chip (Intel Loihi)

Research Intern

Jul 2021 - Nov 2021

Robotics Innovations Lab, IISc

Bangalore, India

  • Used neuromorphic/event cameras to perform dynamic obstacle avoidance in a constrained outdoor space using an autonomous ground vehicle and aerial platforms
  • Conceptualized and developed human-UAV collaboration solutions to perform autonomous collaborative asset inspection in an industrial warehouse/assembly line setup

Summer Research Intern

May 2021 - Jul 2021

Arizona State University

Phoenix, USA

  • Digitized construction spaces using laser scanning and photogrammetry via sensor fusion
  • Deep learning algorithms were used for automated analysis
  • The digital representations were processed to provide insights to builders and stewards

Autonomous System Developer - Intern

Oct 2020 - Apr 2021

Aero2Astro

Chennai, India

  • Developed ROS-based autonomous navigation firmware using Visual Inertial SLAM capable of working in indoor, outdoor, and GPS-denied environments
  • Experiments were conceptualized and conducted for monocular vision SLAM using ORB3 SLAM specifically designed for aerial vehicles

Project Research Intern

Apr 2020 - Jun 2020

Yuan-Ze University

Taoyuan City, Taiwan

  • Deployed multiple ROS packages for KUKA-based manipulators and simulated various ROS Industrial packages using MoveIt
  • Implemented forward and inverse kinematics for a 6 DOF custom-designed manipulator in ROS Industrial

Research Projects

Naval Research - Canadian Armed Forces

Setpoint Attack Detection on a Networked Control System

Designed a command governor cyber-attack detection solution to detect attacks on setpoints/references shared through a network which was tested on a high-fidelity simulation of a fleet of naval vessels.

Naval Research - Canadian Armed Forces

GAN-based Optimal Attack Detection and Generation on GNSS Measurement

Architected and implemented an LSTM-GAN network to detect attacks on GNSS through a discriminator network and generate optimal attack vectors through a generator network that cannot be detected through classical statistical-based cyber-attack detection mechanisms.

Curriculum Vitae & Contact

For a copy of my CV or to discuss research, please get in touch by email.

suryaprakash.rajkumar@concordia.ca
Office EV10.210, GW Campus · Concordia University